Embodied intelligence
Vision-language-action models and robot learning: connecting observations and instructions to useful actions.
PhD researcher · University of Exeter
I'm Quangao Liu. I explore how robots can connect perception, reasoning, and action in the physical world.
My interests span vision-language-action models, multimodal perception, and deploying learning systems on real robots.
01 / Research
Vision-language-action models and robot learning: connecting observations and instructions to useful actions.
RGB-D, thermal, LiDAR, and event cameras, with an interest in active perception and complementary sensor information.
Sensor integration and practical deployment, exploring what it takes to make learning systems work on physical robots.
02 / Selected projects
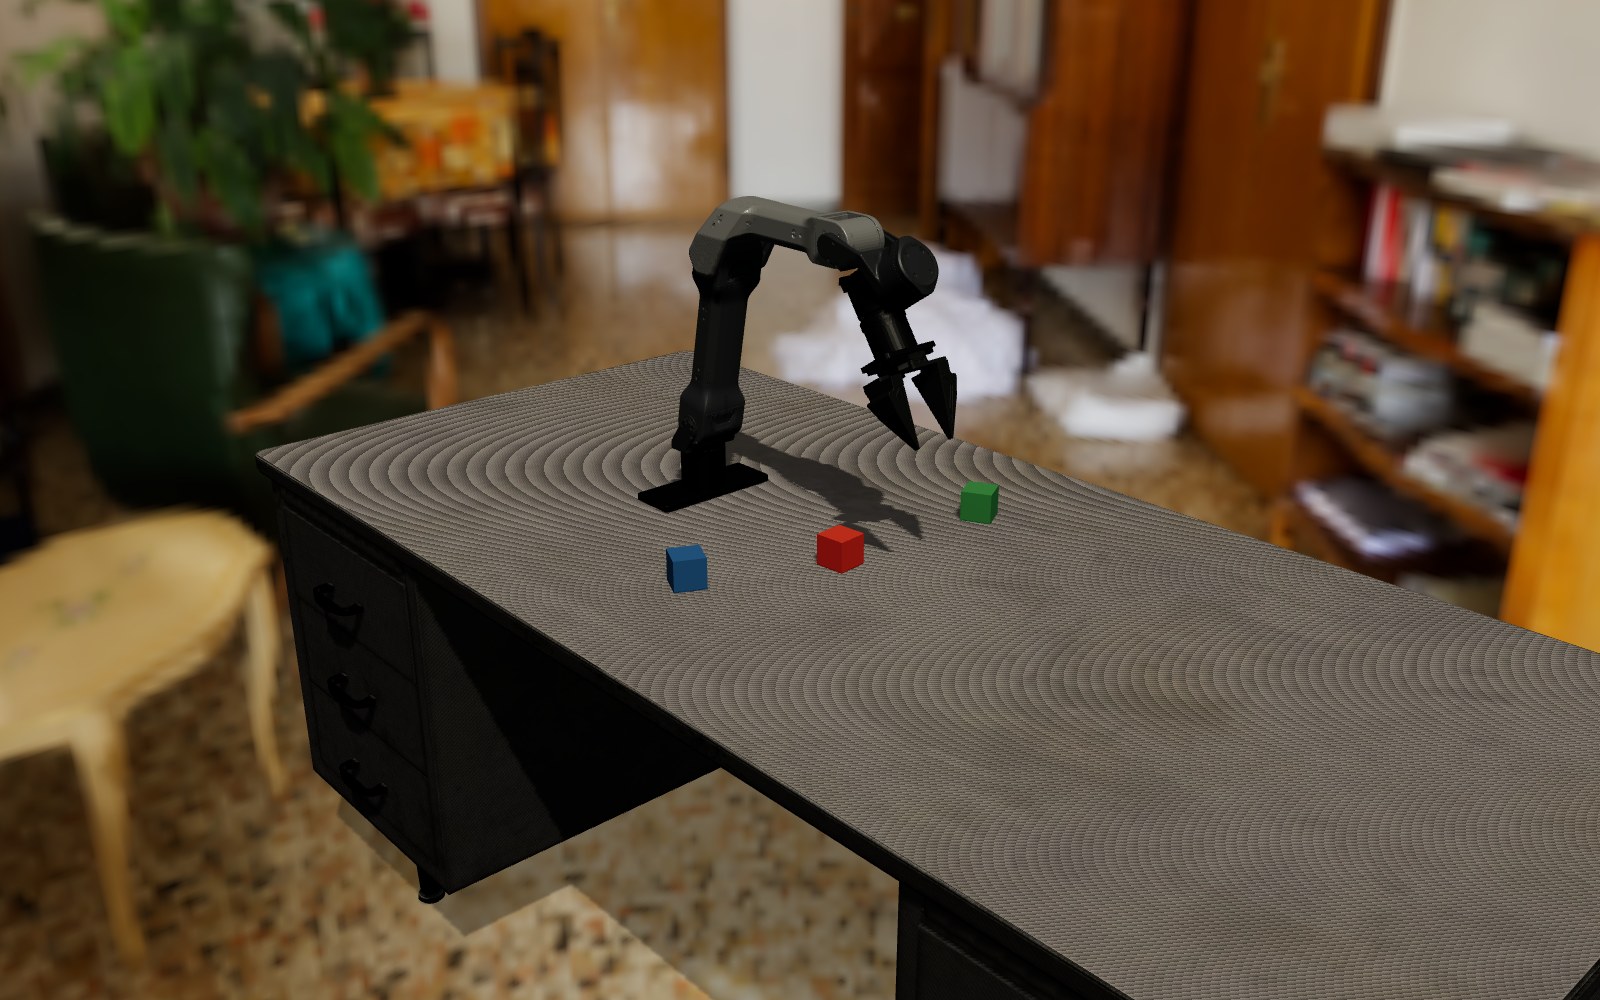
Robot learning / Simulation
A compact, browser-based environment for learning the vision-language-action pipeline.
Simulate robotic manipulation, collect demonstrations, and train lightweight policies with camera observations, language instructions, and robot state.
Explore the projectTime series / Machine learning
Multi-Scale Time-Variable Interaction for Multivariate Time Series Forecasting.
Research code accompanying our 2025 paper in Knowledge-Based Systems.
03 / Selected publications
Information Fusion, 127, Part C, 103923 (2026).
AAAI 2026, Special Track on AI Alignment, 40(44), 37462–37471.
Advances in Neural Information Processing Systems 38 (NeurIPS 2025), Main Conference Track.
Knowledge-Based Systems, 319, 113551.
Knowledge-Based Systems, 309, 112790.
04 / Get in touch
Interested in robotics, embodied AI, or a research collaboration?
I'd be happy to connect.